Hello! Welcome to my little corner of the internet.
I'm a robotics engineer, and I like the problems that show up when robots leave the lab. I enjoy working across the robotics stack, from planning, controls, and estimation to the hardware and systems that tie everything together.
These days, I lead the guidance and control team at a stealth startup in the Bay Area. We build classical and learning-based controllers for autonomous flight, along with the software that makes them run reliably on actual aircraft.
Before that, I studied ECE and Robotics at Carnegie Mellon, where I also spent a good deal of time teaching. Along the way, I worked on robotic manipulation for Ottava at Johnson & Johnson, and at CMU’s Robotics Institute on snake robots for minimally invasive surgery, motion planning for manipulation, and decentralized multi-agent coordination.
I like learning things thoroughly, which often means writing them down. Most of my notes start as attempts to explain something to myself, and I figure they might be useful to someone else too.
Outside of engineering, I enjoy traveling, learning languages, and exploring unfamiliar places - often from behind the wheel of Matilda, my Miata. I occasionally write about my travels, too.
Notes
Selected projects
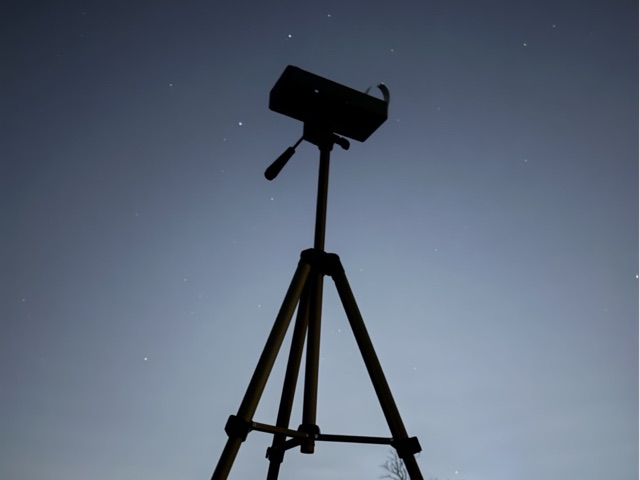
Low-Cost Strapdown Stellar-Inertial Positioning for High-Altitude Platforms
A low-cost stellar-inertial navigation module for positioning without continuous GNSS.
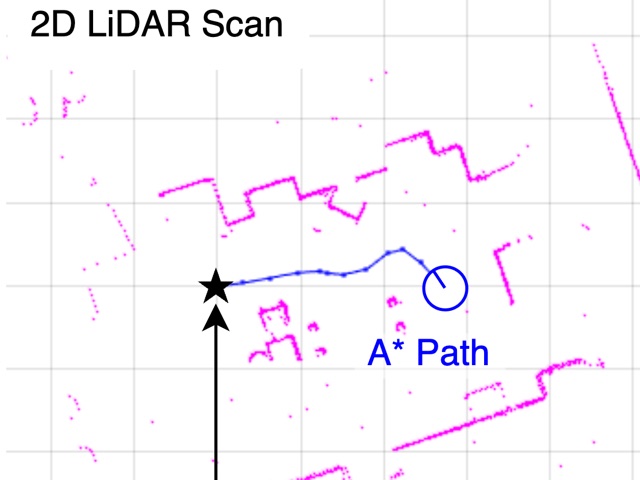
Active SLAM using Deep Reinforcement Learning
RL applied to Active SLAM for balancing exploration with map consistency.
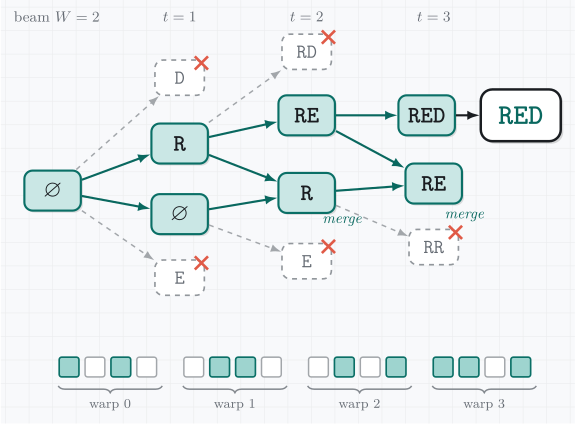
CTC Beam Search with CUDA
A batched GPU beam-search decoder for speech recognition.
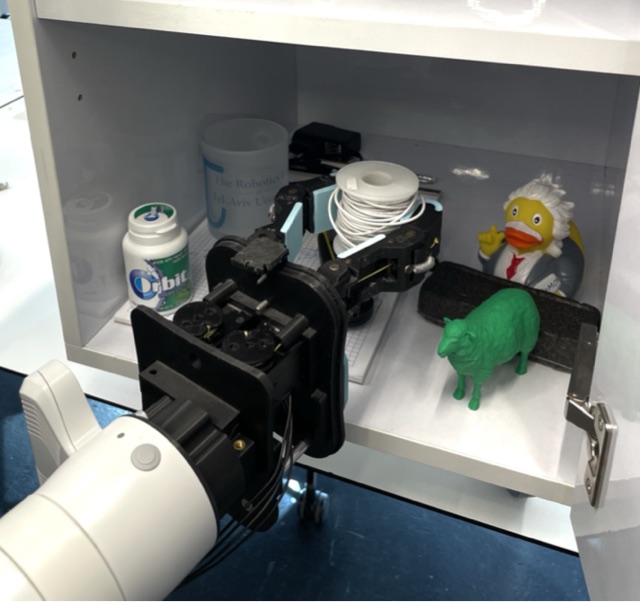
Kinesthetic-based In-Hand Object Recognition with an Underactuated Robotic Hand
Recognizing objects with an underactuated hand from propioceptive information without tactile or visual sensing.
